

Actualmente no hay proyectos en esta categoría.
1

Intelligent Solar Tracking and MPPT Control
Summary:
Development of an MPPT solar tracking system for a low-cost robotic platform, validated in MATLAB/Simulink and microcontrollers.
Technologies:
LQR, LQI, Fuzzy Logic, ANFIS, SMC.
2

Biomimetic Soft Robotic Fish
Summary:
Heading control for trajectory tracking of a cable-driven biomimetic soft robotic fish.
Technologies:
N4SID, Line-of-Sight, PID, FPD+i, MPC.
3

6-DoF Robotic Manipulator with Fuzzy Sliding Control
Summary:
Control of a six-degree-of-freedom robotic manipulator using fuzzy logic and a sliding mode controller for balance and precision.
Technologies:
Fuzzy Logic, Sliding Mode Control.
4
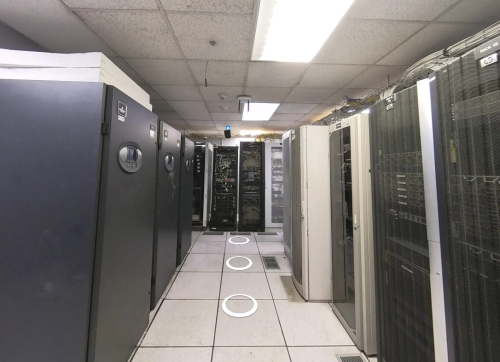
AI-based anomaly detection and prioritization in data centers
Summary:
Smart environmental monitoring and fault prediction platform for mining data centers.
Technologies:
Machine Learning, IA Generativa, Azure, Python.
5

Experimental Balancing Robot Platform
Summary:
Experimental two-wheeled balancing robot platform for evaluating advanced control, autonomous navigation, and sensor fusion.
Technologies:
ESP32, Raspberry Pi, MATLAB, Simulink, Unreal Engine.
6
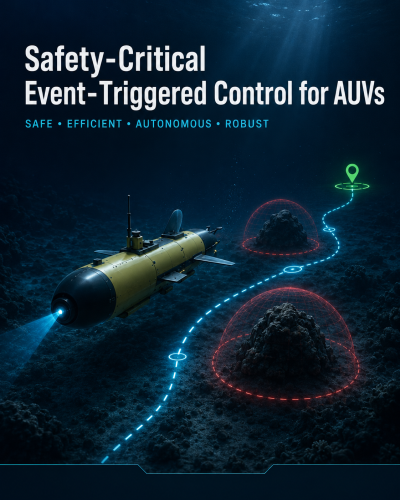
Critical Safety Control for AUVs
Summary:
Dynamic modeling and control of autonomous underwater vehicles, focusing on safe navigation and operation under disturbances.
Technologies:
MATLAB, Python, state-space, automatic control.
7

Autonomous Drone with Fuzzy Control
Summary:
Implementation of improvements in open-source drone controllers using fuzzy logic and sensor integration for obstacle detection.
Technologies:
MATLAB, Fuzzy Logic, open-source drivers.
8
FIU-IAgro: I&D Solution for the Agri-Food System
Summary:
An integrated solution based on nanotechnology, biotechnology, sensor technology, and artificial intelligence to address challenges in the agricultural sector.
Technologies:
Nanoscience, nanotechnology, sensor technology, AI.
9

Robust Control of Underwater Manipulators
Project:
Robust control of underwater manipulators using Sliding Mode Control.
10

CNC Platform for Controller Evaluation
Project:
Design and implementation of an open-architecture CNC platform to compare PID, FLC, and ANFIS controllers in trajectory tracking.
11
Digital Twin
Project:
Digital Twin.
12
Applied Physics in Robotics and Control Systems
Work area:
Physics applied to robotics and control systems.
13
Fuzzy Control for Muscle Fatigue Estimation
Project:
Fuzzy logic controller for calculating muscle fatigue.
Do you have an idea or a challenge?
Partner with us to transform research into real-world solutions for industry and society.