Investigación en control, robótica e inteligencia artificial

Applied research

Research

Advanced control, robotics, and artificial intelligence to develop solutions to real-world engineering challenges

Research and development
Applied research for a smart future
The laboratory conducts research in complex dynamic systems, intelligent control, robotics, artificial intelligence, and autonomous systems.
Our work connects scientific principles, experimentation, and technological development to create solutions applicable to real-world engineering challenges.
Impact
Laboratory indicators
01 8 Research lines
02 20+ Academic projects developed
03 20+ Students involved
04 3+ competitive funds
Fondecyt | Dicyt Regular | Dicyt Post Doc | FONDEF
Our lines of research

Research areas

Eight lines integrating advanced control, robotics, artificial intelligence, energy, and experimentation to address complex engineering challenges.
01

Intelligent control systems

Design of robust, adaptive, optimal, predictive, and nonlinear controllers.
Control MPC dynamic systems
02

Autonomous robotics

Ground and aerial platforms and manipulators capable of operating in dynamic environments.
Navigation Sensors SLAM
03

Underwater robotics and biomimicry

Watercraft and systems inspired by natural organisms for exploration and monitoring.
AUV Biomimetics Marine control
04

Artificial intelligence for industrial systems

Machine learning, computer vision, fault diagnosis, and predictive maintenance.
AI Machine learning Vision
05

Renewable energies and smart systems

Control, management, and optimization of renewable generation, storage, and microgrids.
Solar energy Microgrids Optimization
06

Simulation and experimental validation

Modeling, simulation, prototyping, and experimental validation of complex physical systems.
Simulation Prototyping Validation
07

Soft Robotics

Description pending.
Soft Robotics Flexible materials Performance
08

Control Theory

Description pending.
dynamic systems Stability Control
Teaching and training

Courses taught

CDSCL participates in the academic training of students of Civil Engineering Mechatronics and of the Master's Program in Mechanics at the University of Santiago, Chile.
Mechatronic Civil Engineering Master of Science in Mechanical Engineering FING Cross-Cutting Initiative
01 Curso

Modeling and Simulation

CDSCL · USACH
02 Curso

Smart Control

CDSCL · USACH · Transversal FING
03 Curso

Advanced Robotic Control

CDSCL · USACH · Transversal FING
04 Curso

Complex Dynamical Systems

CDSCL · USACH
Practical training

Laboratories and modules

Laboratory experiences linked to training in robotics and mechatronics.
Laboratory

Industrial Robotics Laboratory

Practical modules

Introduction to Mechatronics Laboratory Modules

Tools and platforms
Technologies we use
MATLAB y Simulink
Modeling and control
Python
AI and processing
ROS 2
Robotic systems
Simscape Multibody
Mechanical simulation
Unreal Engine
Virtual environments
Microcontrollers
ESP32 and Arduino
Sensors and vision
Cameras, LiDAR and IMU
Cloud and artificial intelligence
Azure and cloud services
Applied research
Projects linked to the lines
Initiatives that connect our research areas with concrete applications in robotics, control, artificial intelligence, and energy.
See all projects
Proyecto de seguimiento solar inteligente
AI-based solar tracking and MPPT control
Intelligent system to optimize the orientation and efficiency of solar panels.
Energy Control
Pez robótico biomimético
Biomimetic robotic fish
Flexible platform inspired by aquatic organisms for underwater research.
Biomimetics Robotics
Manipulador robótico industrial
Six-degree robotic manipulator control
Motion control, trajectory planning, and precise manipulation.
Robotics Control
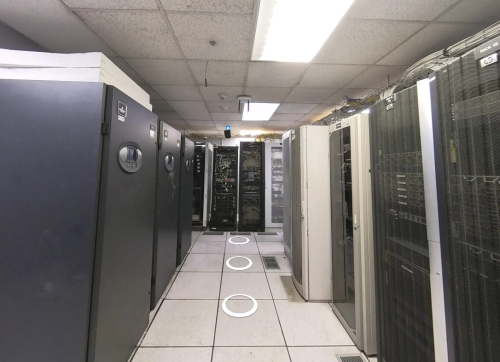
Detección de anomalías en centros de datos mediante inteligencia artificial
Detección y priorización de anomalías en centros de datos con IA
Anomaly detection and predictive maintenance for industrial systems.
AI Monitoring
Proyecto de control autónomo de drones
Autonomous drone control
Robust navigation and control for aerial vehicles in dynamic environments.
Drones Autonomy
Plataforma robótica móvil autoequilibrada
Self-balancing robotic platform
Mobile robot for research in stability, nonlinear control and navigation.
Control mobile robotics

From knowledge to application

How we transform research into impact

Un proceso que conecta desafíos reales, conocimiento científico, experimentación y transferencia tecnológica.

01

real problem

We identify the challenge, its constraints, and the needs of the environment.

02

Modeling and simulation

We model the system and evaluate different scenarios before experimenting.

03

Algorithmic development

We design control, artificial intelligence, and optimization solutions.

04

Experimentation

We integrate prototypes, hardware, and controlled laboratory testing.

05

Results and application

We validate results, document findings, and prepare for their implementation.

06

Impact on the industry

We transfer solutions and knowledge to real-world problems and contexts.

Equipo desarrollando investigación colaborativa en el laboratorio

Collaboration and research

Are you interested in collaborating or conducting research with us?

We work alongside students, researchers, companies, and institutions on projects involving control, robotics, artificial intelligence, and autonomous systems.